

\ AMED
Research
Generative AI for Architected Materials
Architected materials — often called metamaterials — are engineered structures whose extraordinary properties arise not from their base chemistry, but from the deliberate geometric arrangement of their building blocks across multiple length scales. By tailoring geometry, we can program materials to exhibit unusual and often counterintuitive behaviors: negative Poisson’s ratio, ultralight stiffness, extreme energy absorption, or directional wave propagation. These capabilities open transformative possibilities in aerospace, automotive, robotics, biomedical devices, and more.
Generative AI enables inverse design — starting from target properties and producing architectures that meet them — by learning directly from physics-based simulations and embedding constraints into the generative process. In many cases, it can complement topology optimization by using AI-generated candidates as starting points for refinement, augment it by quickly scanning large design spaces before a focused optimization, or replace it when direct optimization becomes computationally prohibitive.
In our lab, we develop machine-learning generative frameworks for the design of metamaterials with complex functionalities. Physics-informed learning lets our models explore design spaces far more efficiently than conventional approaches, while ensuring designs remain high-performing, multi-functional, and manufacturable.
The Design Challenge
Designing metamaterials with complex functionalities is notoriously difficult. Their performance emerges from a nonlinear interplay between geometry, material properties, and loading conditions, within design spaces containing trillions of possibilities. Real-world applications add further complexity:
- Multiple competing objectives (e.g., stiffness vs. energy absorption)
- Manufacturing and defect tolerance constraints
- The need for tunability and programmability
Traditional workflows — such as parametric sweeps, intuition-driven iterations, topology optimization, and brute-force FE simulations — have been powerful tools for structural and materials design. However, they are inherently limited when dealing with vast discrete design spaces, highly nonlinear behaviors, or multi-objective trade-offs. Topology optimization, for example, can yield excellent designs for a single performance metric under idealized conditions, but struggles to incorporate complex manufacturing rules, multi-functional requirements, or large-scale defect tolerance.
Why Generative AI Changes the Game
Generative AI enables inverse design — starting from target properties and producing architectures that meet them — by learning directly from physics-based simulations and embedding constraints into the generative process. In many cases, it can complement topology optimization by using AI-generated candidates as starting points for refinement, augment it by quickly scanning large design spaces before a focused optimization, or replace it when direct optimization becomes computationally prohibitive.
In our lab, we develop machine-learning generative frameworks for the design of metamaterials with complex functionalities. Physics-informed learning lets our models explore design spaces far more efficiently than conventional approaches, while ensuring designs remain high-performing, multi-functional, and manufacturable.
Design for Complex Functionalities: From Isotropic Buckling Resistance to Multi-Objective Wave Control
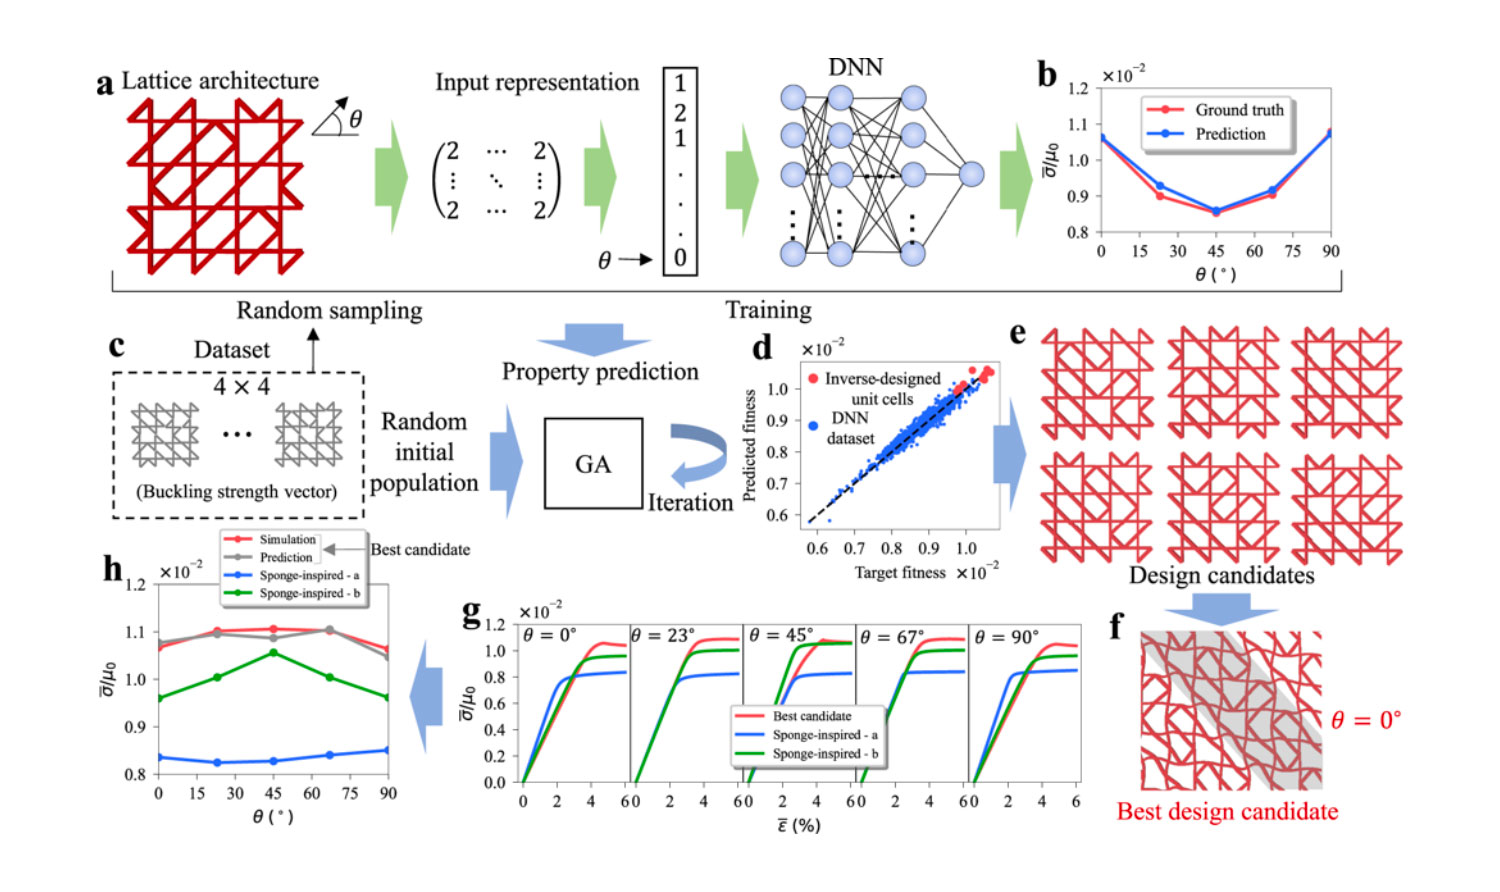
Structural instabilities often govern the mechanical response of truss-based metamaterials. Designing for such complex, nonlinear phenomena is highly challenging for traditional approaches — including topology optimization — which struggle to capture the full design space and nonlinear interactions. By combining deep neural networks with evolutionary algorithms, we created two-dimensional architectures optimized to resist buckling uniformly under loading from any direction — a capability that is virtually impossible to achieve with conventional design methods.
Moving beyond simple 2D structures, we developed GraphMetaMat — a generative graph neural network that enables the design of 3D metamaterials tailored to virtually any nonlinear mechanical response. GraphMetaMat can produce architectures with programmable stress–strain curves and controllable vibration transmission, while rigorously accounting for geometric constraints, manufacturing feasibility, and defect tolerance. This ensures that the generated designs are not only high-performing in simulations but also practical for real-world fabrication.

Most recently, we extended GraphMetaMat to the multi-objective inverse design of 3D metamaterials with tunable band structures. This advancement enables the simultaneous optimization of wave-propagation characteristics in multiple directions, paving the way for multifunctional and adaptive materials with unprecedented control over their dynamic behavior.
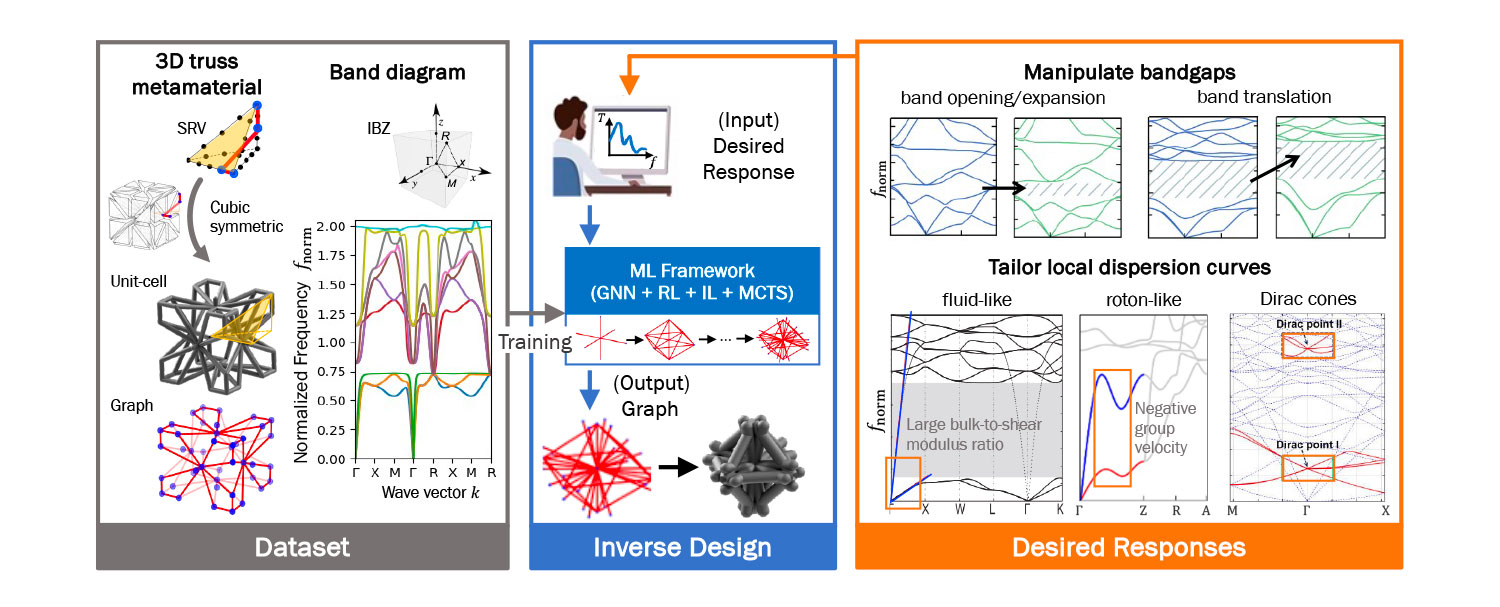
Together, these advances bring us closer to fully automated, physics-aware, and manufacturable metamaterial design pipelines — compressing the path from concept to fabrication from months or years to just days or weeks.
Publications
- Marco Maurizi, et al., Inverse design of truss lattice materials with superior buckling resistance (2022). npj Computational Materials.
- Marco Maurizi, Derek Xu, Yu-Tong Wang, et al., Designing metamaterials with programmable nonlinear responses and geometric constraints in graph space (2025). Nature Machine Intelligence.
- Yu-Tong Wang, Marco Maurizi, et al., Inverse Design of three-dimensional metamaterials with tunable band structure (2025). In preparation.
Robotic Matter
Modern engineered materials are evolving beyond static mechanical properties to become active, dynamically responsive systems — capable of sensing, actuating, and adapting to their environment. At AMED, we refer to this emerging direction as Robotic Matter: architected material systems in which geometry, material physics, sensing, actuation, and intelligence are co-designed from the beginning.
A first step toward this vision is the design of piezoelectric truss metamaterials, where the architecture itself controls anisotropic electromechanical coupling. Piezoelectric materials are particularly powerful because they naturally connect mechanical deformation and electrical response, enabling both sensing and actuation within the same physical substrate.
High-throughput computational screening has recently identified roughly 3,000 natural piezoelectric crystals. However, such discoveries are inherently constrained to chemically realizable crystal structures — materials shaped by evolutionary processes and atomic-scale assembly. Their symmetry-derived piezoelectric tensors are fixed, and tuning them is difficult, often relying on serendipity. In contrast, truss metamaterials allow precise tuning of piezoelectric anisotropy by altering the geometric arrangement of connected struts. While previous efforts have engineered architectures to target selected piezoelectric coefficients, the explored design spaces have remained limited.
To break this limitation, we developed a graph neural network–guided design framework for complex 3D truss metamaterials with tailorable anisotropic electromechanical coupling, unlocking a vastly larger and richer space of achievable piezoelectric responses. This work shows how AI can move piezoelectric design beyond the discovery of existing materials and toward the programmable design of new functional architectures.
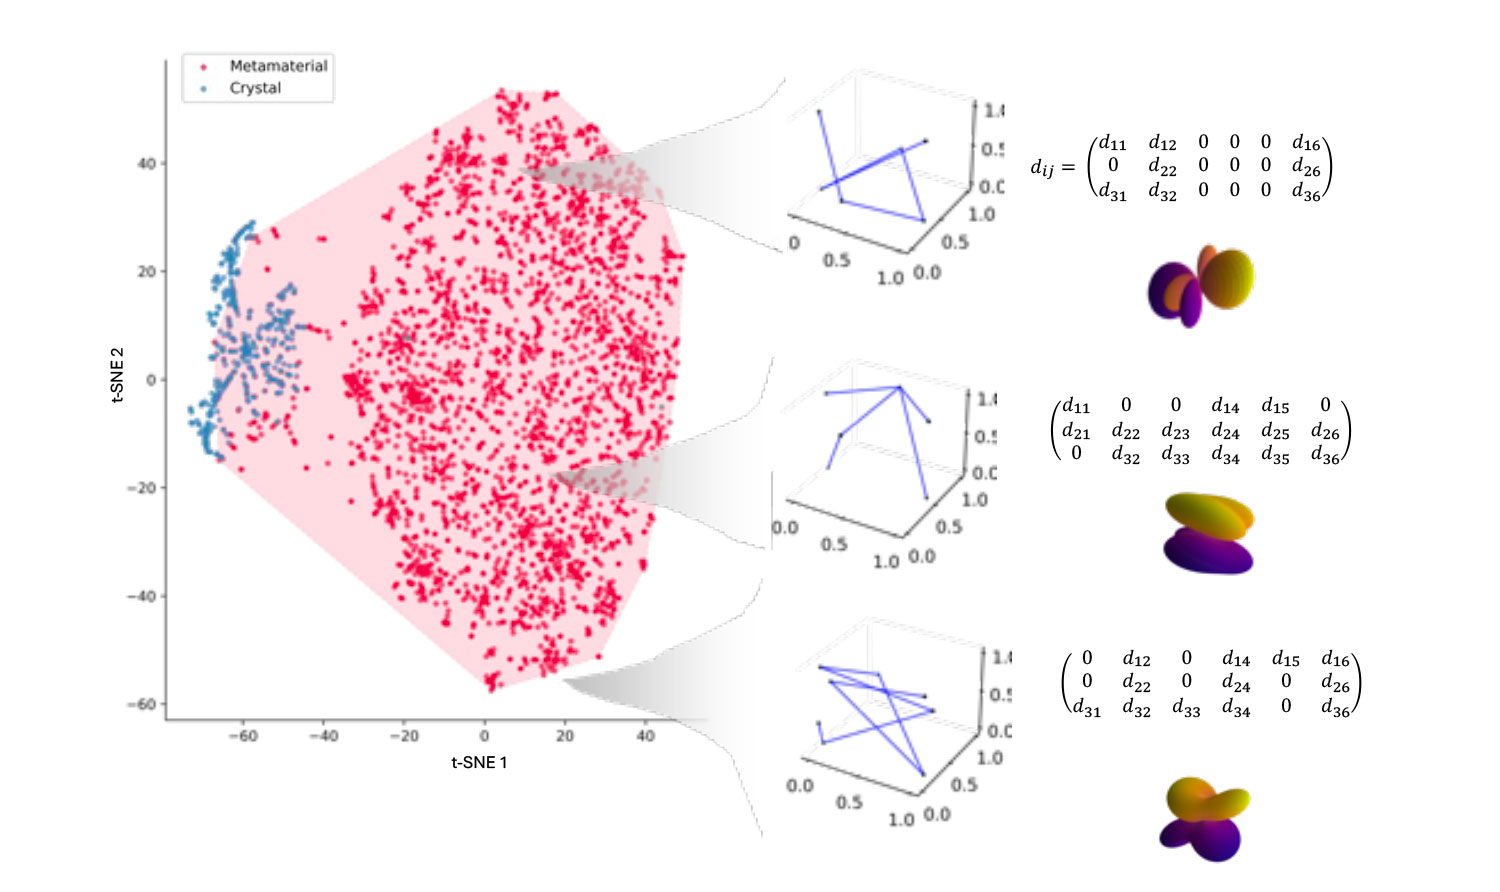
Yet Robotic Matter requires going beyond static or quasi-static material properties. In real devices, piezoelectric materials often operate under dynamic conditions — for example, in vibration sensing, energy harvesting, wave control, haptics, adaptive structures, and robotic systems. While the intrinsic properties of bulk piezoelectric materials are largely frequency-independent, the effective properties of metamaterials can vary significantly with frequency because of their architecture.
To address this gap, we are developing AI-based, dynamics-aware design frameworks that integrate frequency-dependent behavior into the generative process. The goal is to design piezoelectric metamaterials that remain robust and functional across realistic operating conditions, rather than only optimizing idealized static properties.

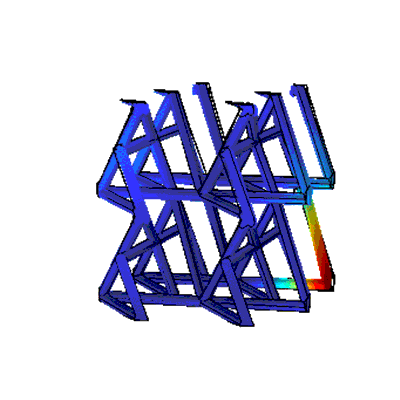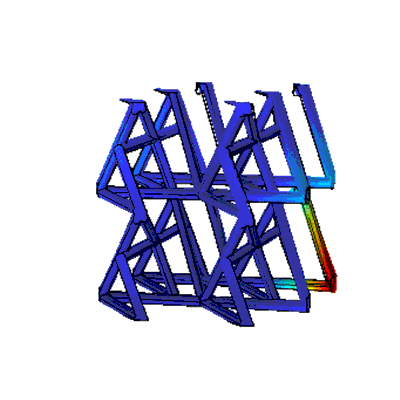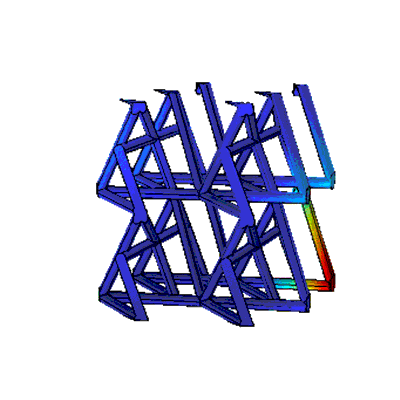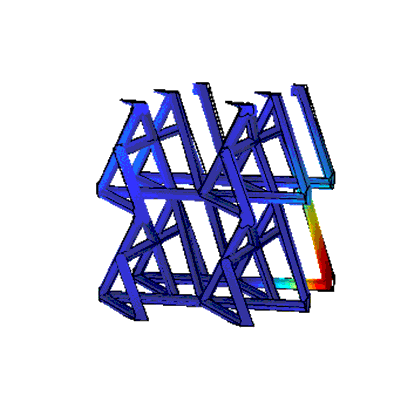
Building on this foundation, our Robotic Matter project aims to create piezoelectric robotic matter: architected solids that can sense deformation, actuate their shape, and modulate their behavior through distributed electromechanical feedback. Instead of treating the material as a passive body controlled by external sensors, motors, and centralized electronics, we aim to embed sensing and actuation directly into the material architecture.
This requires co-designing lattice topology, strut geometry, piezoelectric polarization, electrode patterns, voltage actuation, and local control rules. The material is no longer only a structure with programmable properties; it becomes a physical platform in which mechanical function, transduction, and computation are coupled. In this view, deformation is not just an output of the system — it is also a source of information that can guide response.
Our long-term objective is to move beyond today’s piezoelectric metamaterials and adaptive solids toward material systems with embodied intelligence: structures that can self-sense, respond to contact, adapt their actuation, stabilize motion, or change behavior when interacting with their environment. This opens a route toward robotic materials whose intelligence is not simply added through external control, but emerges from the designed coupling between architecture, physics, and AI.
Publications
- Marco Maurizi, et al., The Piezoelectric Effect on Metamaterials (2025). In preparation.
- Rodolfo Subert, Marco Benedetti, and Marco Maurizi, Robotic Matter (2025). Work in progress.
AI Physics Engines
High-fidelity finite element (FE) simulations remain essential for predicting stress, strain, deformation, and other physical fields in complex materials and engineering systems. However, their computational cost becomes a major bottleneck when exploring the vast design spaces of architected metamaterials, where each new geometry, boundary condition, loading scenario, or material parameter may require a new expensive solve. Traditional surrogate models can accelerate specific simulations, but they often remain tied to a fixed geometry class or training distribution, limiting their ability to generalize like true numerical solvers.
Our work on GNN-based surrogate mechanics was a first step toward this broader vision. By representing FE meshes as graphs, where each mesh node becomes a graph node with geometry- and physics-informed features, we developed models that learn directly from simulation data while preserving full geometric fidelity. This enables accurate full-field predictions of stress, strain, and displacement for unseen designs orders of magnitude faster than conventional FE solvers, supporting rapid design-space exploration, optimization, and inverse design.
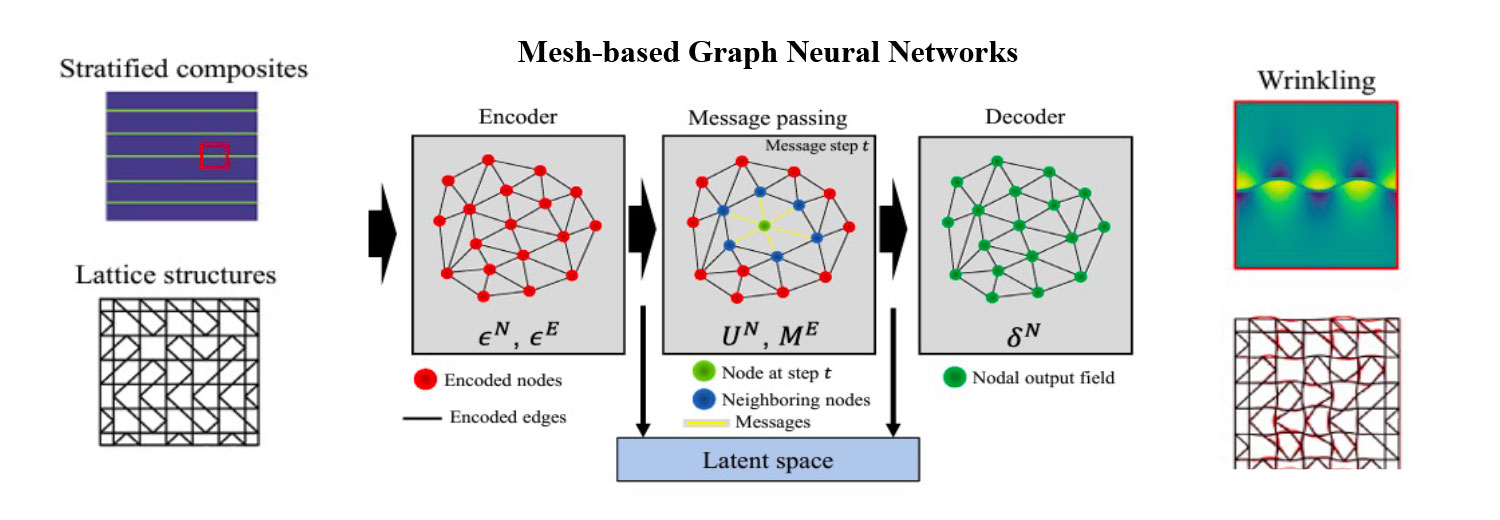
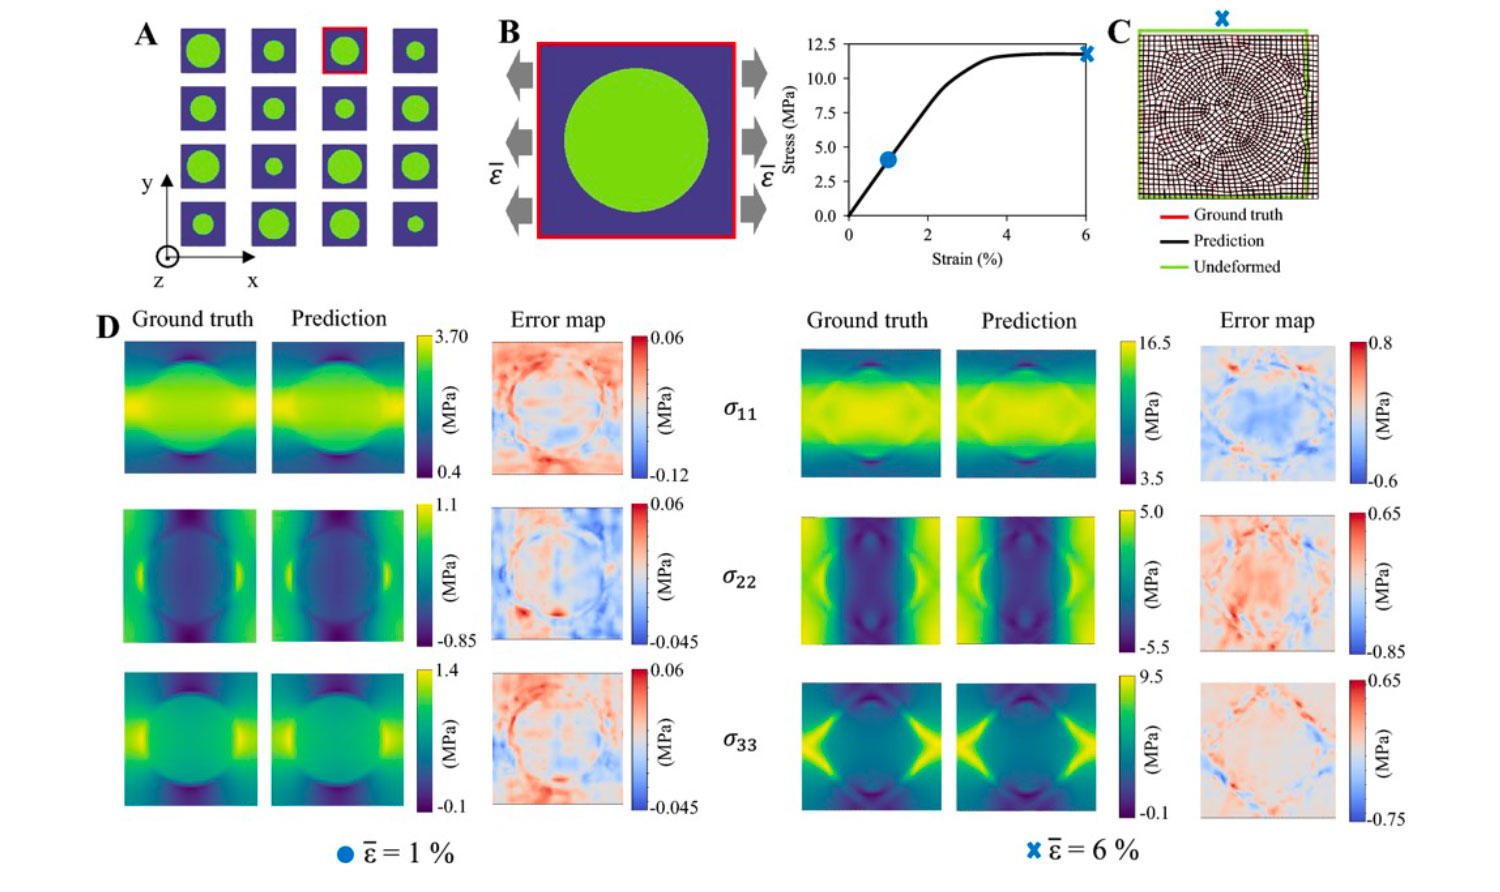
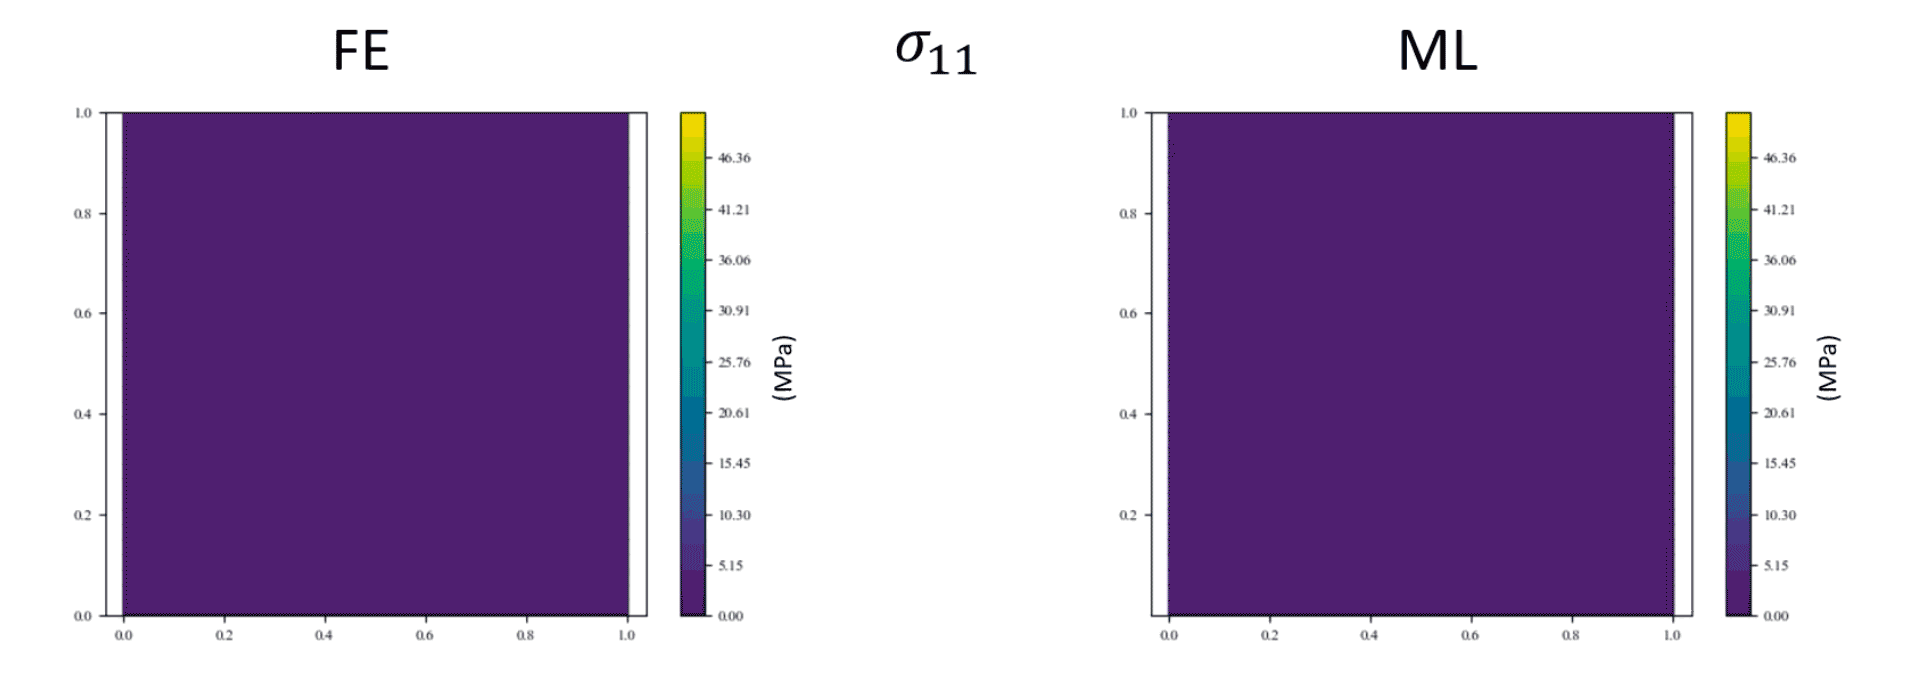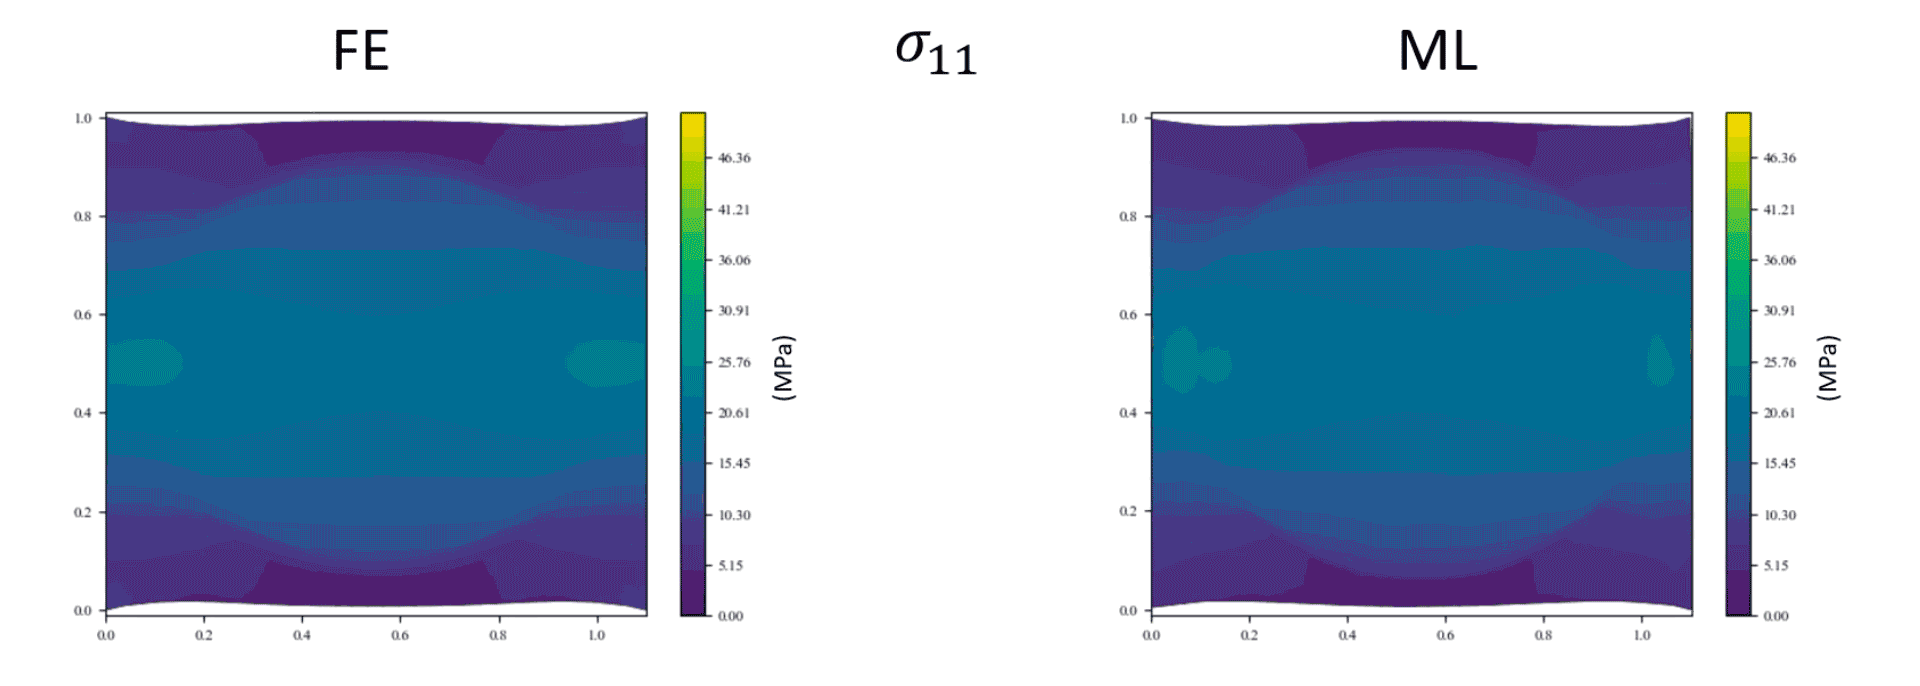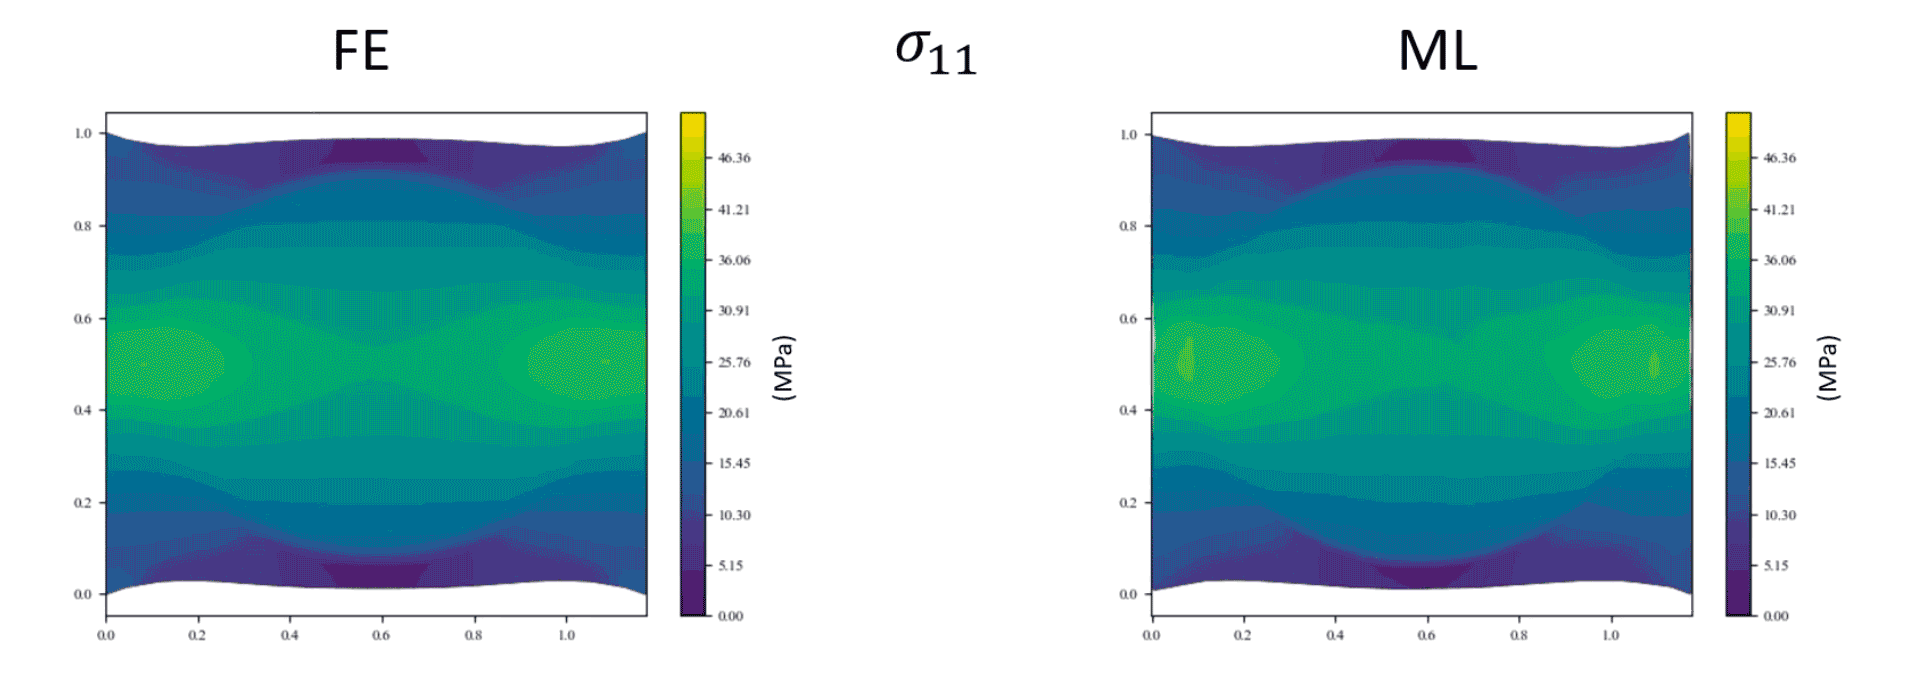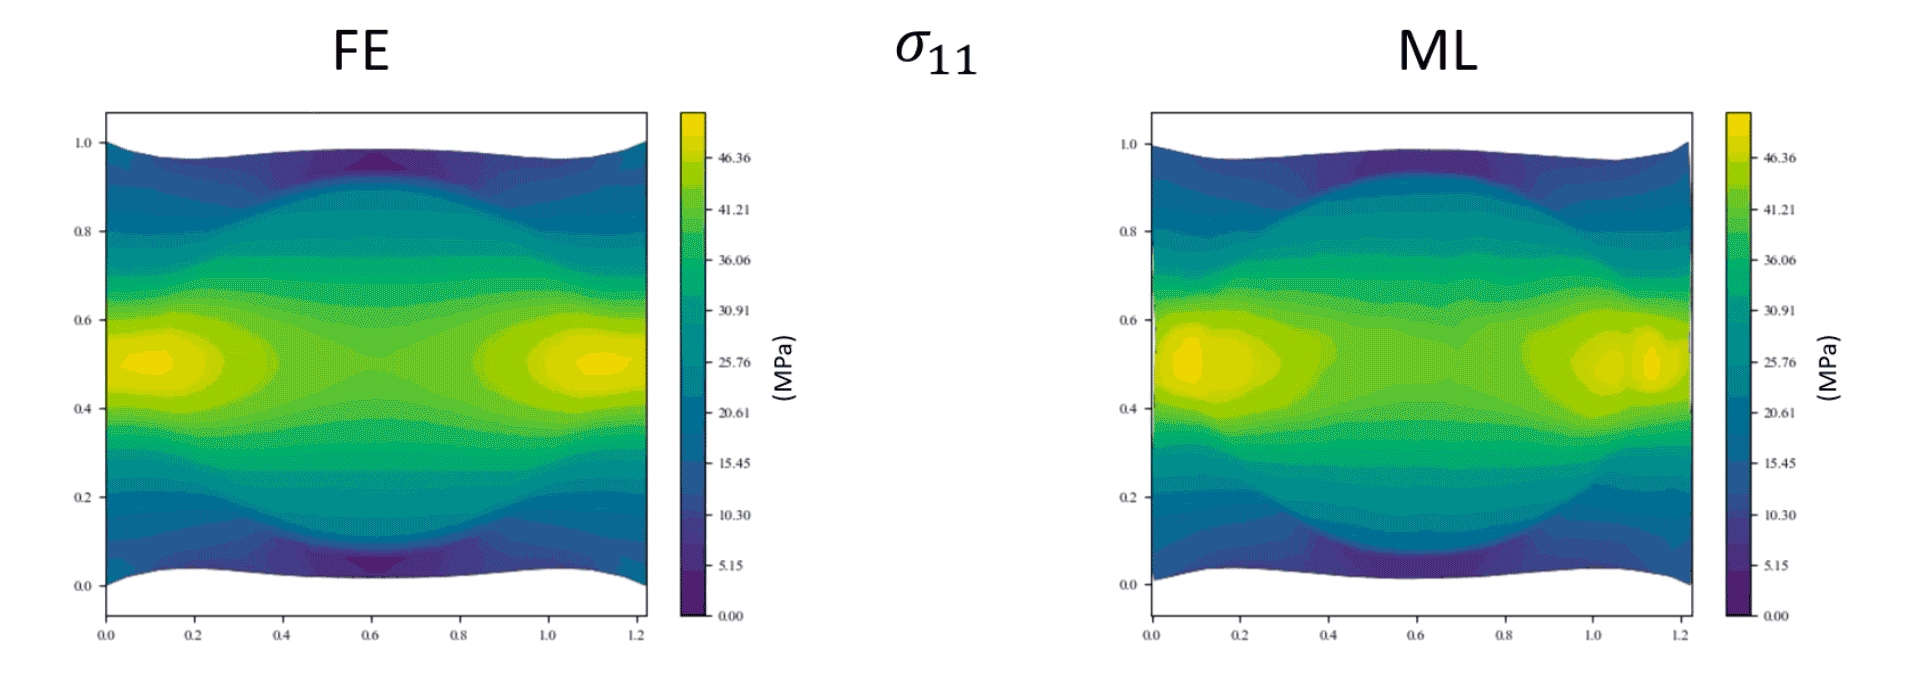
Building on this foundation, we are now developing AI Physics Engines: learned computational frameworks that aim to solve PDE-governed physical problems across changing geometries, boundary conditions, scales, and material coefficients. In our recent work on Neural-Schwarz Tiling (NEST), we move beyond global, problem-specific neural surrogates by learning reusable local physical solvers on small voxelized patches and composing them into global solutions through classical domain-decomposition principles. Instead of retraining a new model for every geometry family, NEST tiles unseen domains into overlapping local neighborhoods, applies the learned solver patch by patch, and enforces global consistency through Schwarz iteration. This local-to-global strategy opens a path toward fast, reusable, and geometry-universal AI solvers that retain the flexibility of numerical methods while dramatically accelerating simulation-driven materials and engineering design.
Publications
- Marco Maurizi, et al., Predicting stress, strain and deformation fields in materials and structures with graph neural networks(2022). Scientific Reports.
- Paolo Secchi, Daniel S. Balint, and Marco Maurizi, Neural-Schwarz Tiling for Geometry-Universal PDE Solving at Scale (2025). Arxiv pre-print.
AI End-to-End Design of Devices
Designing new devices and physical systems still requires years of human-intensive research and development, largely because final system-level requirements must be translated across multiple coupled design layers, including materials, geometry, structure, fabrication constraints, and algorithmic workflows. Recent advances in AI, and especially the rise of large language models and foundation models, are changing how we think about engineering design: from a sequential, expert-driven process to an integrated, AI-assisted pipeline that can connect requirements, simulation, optimization, and validation.
Motivated by this challenge, we focus on the end-to-end design of acoustic transducers for 3D image reconstruction. In particular, we are developing AI-assisted design pipelines for piezoelectric micromachined ultrasonic transducers (PMUTs), where device geometry, material properties, actuation parameters, and array configurations must be jointly optimized to achieve target acoustic fields and imaging performance. This work combines physics-based simulation, data-driven surrogate models, inverse design, and automated optimization to accelerate the discovery of compact, high-performance ultrasound devices, with applications in biomedical imaging, sensing, and intelligent robotic systems.
